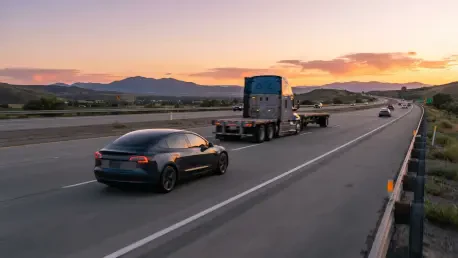
Maintaining safety while executing aggressive maneuvers like overtaking requires a sophisticated integration of kinematic modeling and dynamic state tracking. In the current landscape of 2026, autonomous driving technology has progressed significantly, yet a persistent challenge remains in the rigid divide between high-level decision-making and low-level motion control. Most standard architectures rely on static models and rule-based systems that, while mathematically sound and capable of maintaining lane stability, often struggle to adapt to the spontaneous and nuanced nature of human intentions. These systems typically operate on fixed objective functions, making it difficult for a vehicle to alter its behavior—such as its following distance or aggressiveness—based on real-time verbal instructions. This lack of flexibility creates a functional barrier between the vehicle’s automated logic and the passenger’s immediate preferences, often leading to a driving experience that feels disconnected or overly conservative. To bridge this gap, the introduction of ChatMPC represents a pivotal shift, merging Natural Language Processing with dynamic Model Predictive Control. This framework establishes a closed-loop pipeline capable of translating natural language commands into continuous mathematical parameters, ensuring that the vehicle remains responsive to human input without compromising the safety protocols that define modern transportation.
The Hierarchical Framework: Bridging Semantic Intent and Control
The structural foundation of the ChatMPC system is built upon a hierarchical design that facilitates a seamless transition from human speech to mechanical execution. This architecture is divided into two primary components: the Intent Recognition Module and the MPC Controller Module. The Intent Recognition Module acts as the primary interface, capturing the semantic meaning of human commands rather than merely identifying isolated keywords. This is a critical distinction, as traditional voice interfaces often fail when users employ varied phrasing or informal syntax. By focusing on the underlying intent, the system can distinguish between a request to “hurry up” and a more specific instruction to “overtake the vehicle ahead.” Once an intent is identified, it is passed to the MPC Controller, which translates this high-level understanding into physical motion by updating the vehicle’s optimization problems. This includes adjusting target trajectories and modifying operational constraints in real-time, allowing the vehicle to exhibit behaviors that align precisely with the passenger’s verbalized expectations.
The technical complexity of the intent recognition process relies heavily on Sentence-BERT, a pre-trained transformer model capable of handling millions of parameters to ensure linguistic accuracy. When a user provides a command, the system transforms the input into a dense, high-dimensional vector that encapsulates the semantic essence of the sentence. By utilizing a K-Nearest Neighbors classifier, the framework compares this vector against a comprehensive library of reference intents. This method allows the system to accurately categorize complex maneuvers even when the user employs diverse or ambiguous phrasing. For instance, whether a passenger says “let’s pass this truck” or “can we get ahead of the car in front,” the system maps both inputs to the same overtaking intent. This high level of abstraction is necessary for the vehicle to operate in diverse social and linguistic environments where human communication is rarely standardized. By anchoring the control logic in semantic vectors rather than rigid code, the framework achieves a degree of adaptability that was previously unattainable in earlier iterations of autonomous driving software.
Linguistic Adaptation: Enhancing Robustness through Data Augmentation
To ensure that the framework is robust enough to handle the vast array of human speaking styles, researchers have implemented extensive data augmentation strategies within the 2026 development cycle. Starting with a base set of foundational commands, the library was expanded using semantic substitution, sentence reorganization, and back-translation techniques. This process ensures that the system can recognize a command whether it is phrased as a direct imperative or a polite request. Such linguistic flexibility is essential for creating a system that feels natural to a wide range of users, from those who prefer concise instructions to those who use more conversational language. By training the model on a diverse dataset that includes synonyms and varied syntactic structures, the framework minimizes the risk of misinterpretation, which is a vital safety consideration when the vehicle is operating at high speeds. This development ensures that the transition from human thought to vehicular action is as frictionless as possible, moving away from the “command-and-control” style of older interfaces toward a more collaborative partnership between human and machine.
The dynamic nature of the MPC formulation is what allows these recognized intents to manifest as physical changes in the vehicle’s driving profile. Once an intent such as “car-following” is identified, the controller automatically adjusts its longitudinal and lateral references to meet the specific requirements of that state. For example, the system may set a specific following distance of fifteen meters while tightening the control time steps to ensure a rapid response to any sudden braking by the lead vehicle. If the intent shifts to “overtaking,” the controller reconfigures its planning horizon and widens its lateral constraints to facilitate a safe and efficient lane change. This ability to re-parameterize the underlying optimization problem on the fly is what differentiates this framework from static control systems. It allows the vehicle to be aggressive when requested—such as when navigating a busy highway—and cautious when the passenger prioritizes comfort or fuel efficiency, all while operating within the safe limits established by the kinematic model.
Motion Synthesis: The Role of Model Predictive Control
To maintain physical feasibility during these dynamic maneuvers, ChatMPC employs a two-degree-of-freedom bicycle kinematics model that serves as the mathematical backbone for all movement. This model simplifies the vehicle’s dynamics by assuming that the tires do not slip and that the velocity vectors remain aligned with the orientation of the wheels. By focusing on the vehicle’s longitudinal and lateral positions, yaw angle, and velocity, the system can calculate precise maneuvers without overwhelming the onboard processor. This mathematical foundation is crucial because it ensures that every trajectory generated is within the actual physical capabilities of the car. In the context of 2026 hardware, this model allows for high-frequency updates that are necessary for maintaining stability during complex maneuvers like rapid lane changes or emergency swerving. The use of a deterministic kinematic model provides a layer of predictability that purely neural-network-based driving models often lack, giving both passengers and regulators confidence in the vehicle’s decision-making process.
Safety is not merely an external constraint but is integrated directly into the optimization process through a multi-circle collision avoidance model. In this approach, both the controlled vehicle and other objects on the road are represented by geometric circles centered at their respective front and rear axles. The controller enforces a strict minimum distance between these circles, effectively preventing any overlap during complex diagonal maneuvers that might confuse simpler point-mass models. This geometric representation is significantly more computationally efficient than complex elliptical models, allowing the vehicle to make safety-critical decisions in milliseconds while navigating through dense traffic. By treating collision avoidance as a hard constraint within the Model Predictive Control framework, the system ensures that no matter how “aggressive” a human command might be, the vehicle will never execute a maneuver that violates the fundamental safety buffer. This creates a fail-safe environment where the human provides the “what” and “how fast,” while the MPC provides the “how” and “how safe.”
Performance Validation: Real-Time Efficiency and Accuracy
Experimental results conducted on high-performance simulation platforms during 2026 have validated the effectiveness of the ChatMPC framework across various driving scenarios. In car-following tests, the vehicle demonstrated the ability to reach target following distances in under two seconds with a tracking error of less than one percent. During more complex overtaking maneuvers, the system successfully managed lane changes and passed lead vehicles with high precision, maintaining steady-state tracking even as environmental variables changed. These tests confirm that the framework can translate qualitative human language into quantitative, high-performance driving actions that feel both smooth and intentional. The precision of these maneuvers suggests that the mapping between the S-BERT semantic vectors and the MPC cost functions is highly accurate, allowing the vehicle to mimic the decision-making patterns of an expert human driver while maintaining the tireless vigilance of an automated system.
Beyond maneuver accuracy, the system is designed for extreme computational efficiency, which is a prerequisite for deployment in mass-market autonomous vehicles. Operating at a frequency of 20 Hz, the MPC solver consistently completes its calculations within a 13.5-millisecond average, well within the 50-millisecond time budget allocated for each cycle. This speed is critical for real-time applications where even a slight delay in processing could lead to a safety risk or a jerky driving experience. The online intent recognition stage is similarly rapid, typically executing in about 0.33 seconds, ensuring that the transition from a human’s spoken word to the vehicle’s physical response is nearly instantaneous. This level of performance indicates that the framework is ready for integration into the next generation of vehicular edge computing platforms, where low latency and high reliability are the primary benchmarks for success. The efficiency of the specialized S-BERT encoder proves that massive, resource-heavy language models are not always necessary for specialized tasks like vehicular control.
Strategic Evolution: Advancing Adaptive Autonomous Systems
The development of ChatMPC has addressed significant limitations found in earlier automotive interfaces, which were often restricted to simple tasks like adjusting climate control or basic navigation. Unlike some modern attempts that use large-scale language models with high latency, this framework utilized a specialized, smaller encoder that was much better suited for high-speed vehicle control. This ensured that the integration of human language did not come at the cost of the vehicle’s stability or its ability to respond to immediate environmental hazards. The project succeeded in proving that natural language could serve as a reliable control signal when backed by a robust mathematical framework. By shifting the focus from rigid automation to human-centric interaction, the system provided a model for how future autonomous platforms could handle the unpredictability of human passengers while operating in a complex, multi-agent environment.
The research established a foundation for future iterations that are expected to expand into multilingual support and incorporate reinforcement learning from human feedback. This would allow the system to refine its driving style based on how passengers rate the comfort or efficiency of its maneuvers over time, leading to a truly personalized AI driver. Additionally, engineers should aim to extract even more fine-grained parameters from speech, enabling the vehicle to follow highly specific instructions such as “stay exactly ten meters behind that red truck.” Industry leaders and developers should consider implementing similar hierarchical structures to bridge the gap between semantic understanding and physical control. By continuing to refine the link between human reasoning and mechanical execution, the automotive industry can move toward a future where vehicles are not just tools for transportation, but intelligent partners capable of understanding and executing the nuanced desires of their occupants.