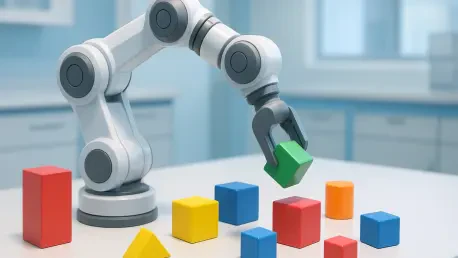
Success in robotic autonomy requires more than visual recognition; it demands a sophisticated understanding of the trade-offs between information gathering and task execution. The transition of artificial intelligence from the digital realm into the physical world represents one of the most significant challenges in modern engineering. While large language models have achieved a “GPT moment” by demonstrating universal utility in processing text and code, embodied AI—the intelligence powering physical robots—is still searching for its equivalent breakthrough. To move beyond choreographed laboratory demonstrations and into the unpredictable environments of factories and homes, these systems must bridge the gap between theoretical vision-language-action models and the harsh realities of physical execution. Achieving this milestone requires more than just scaling neural networks; it demands a fundamental shift in how robots perceive and interact with their surroundings. Unlike a chatbot that operates in a world of static data, a robot exists in a state of constant physical ambiguity.
Navigating Physical Uncertainty and Interaction
The Frontier of Interactive Perception: Part 1
The primary obstacle to reliable embodied AI is the inherent ambiguity of the physical world, which often requires “interactive perception” to resolve. When a robot encounters an object, visual sensors might provide an incomplete picture, such as failing to detect the weight of a box or the friction of a mechanical part. A truly intelligent system must employ “probing”—the ability to perform intentional, exploratory actions designed specifically to gather more information. This capacity to recognize when an internal world model is incomplete and to execute a diagnostic movement is what separates a reactive machine from a rational, embodied agent. As of 2026, developers are focusing on training models that do not just guess based on pixels but actively test their environment to verify hypotheses. This shift transforms the robot from a passive observer into an active investigator capable of handling unforeseen variables in real time.
The Frontier of Interactive Perception: Part 2
Furthermore, the intelligence of a robot is defined by its ability to manage the action-outcome interface, where sensory input meets physical consequence. In industrial settings, a robot must decide whether to proceed with a task or pause to investigate a discrepancy, such as haptic resistance that contradicts visual alignment. This level of sophisticated decision-making requires the robot to act as an information-seeking entity, ensuring that its interpretation of the environment is accurate before committing to a high-risk or high-force maneuver. By integrating tactile feedback with visual streams, modern foundational models can now better predict the results of their interventions. The challenge lies in ensuring these models can generalize this “physical intuition” across various materials and lighting conditions without requiring extensive retraining for every new workspace or object. Achieving this fluidity is essential for moving from static automation to dynamic dexterity.
The Economic and Technical Architecture of Autonomy
Calibrated Uncertainty: Part 1
For embodied AI to be commercially viable, it must operate within a mathematical framework of utility and cost. Every exploratory “probe” or diagnostic action costs time and energy, meaning the robot must autonomously calculate whether the potential increase in success rate justifies the expense of gathering more data. This requires “calibrated uncertainty,” a state where the AI has a statistically accurate understanding of its own confidence levels. A “GPT moment” will occur when robots can reliably predict their own failure points and choose the most efficient path to success without constant human oversight. Between 2026 and 2028, the industry expects a surge in “probability-aware” architectures that prioritize safety and efficiency in high-stakes environments. These systems aim to reduce the overhead of manual intervention by knowing exactly when to ask for help and when to trust their own sensors, thereby optimizing the total cost of autonomous operation.
Calibrated Uncertainty: Part 2
The integrity of the underlying training data serves as the foundation for this level of autonomy. Currently, the robotics field struggles with “noisy” data caused by inconsistent sensor calibration, hardware wear, and unrecorded human interventions during training sessions. If a model learns from a dataset where a human safety controller intervened without the action being logged, the AI may develop false correlations between its movements and successful outcomes. Standardizing data across different robotic platforms and ensuring a clear distinction between requested and executed commands is essential for building generalist models that can transfer skills between machines. This involves creating universal data formats that account for different coordinate frames and sensor sensitivities. Without this level of rigorous data hygiene, the scaling laws that powered the success of large language models cannot be effectively applied to the physical world, where every millimeter of error carries a tangible consequence.
Defining Success Through Industrial Benchmarks
Repeatable Performance: Part 1
The final hurdle to achieving a transformative breakthrough in embodied AI is the establishment of rigorous, standardized performance metrics that prove economic value. In the manufacturing sector, “impressive” is secondary to “reliable”; therefore, AI systems must be evaluated against strict cycle-time limits and damage thresholds. A robot’s success is not merely completing a task, but doing so within the same time constraints as traditional automation while providing explicit uncertainty intervals that state how often it will require human assistance. To gain widespread adoption, AI-driven robotics must move away from comparing themselves to poor-performing baselines and instead prove their superiority over established active-sensing methods. This involves demonstrating physical robustness against sensor contamination and mechanical wear, ensuring the system remains functional in gritty, real-world conditions like those found in heavy industry.
Repeatable Performance: Part 2
Stakeholders in the robotics industry identified that the path toward generalist intelligence required a transition from isolated task engineering to systemic robustness. Companies began prioritizing the collection of edge-case data, ensuring that robots were prepared for the one-percent of scenarios that typically lead to catastrophic failure in traditional systems. This approach involved deploying diverse sensor suites that could maintain high-fidelity perception even when primary cameras were obscured or degraded. Furthermore, the development of simulation-to-real transfer techniques allowed for the rapid testing of physical interaction policies in a risk-free digital environment before physical deployment. By 2026, the focus shifted toward creating modular AI controllers that could be swapped across different hardware configurations with minimal calibration. These steps ensured that embodied AI moved toward a future where universal utility became a quantifiable standard rather than a theoretical ambition.